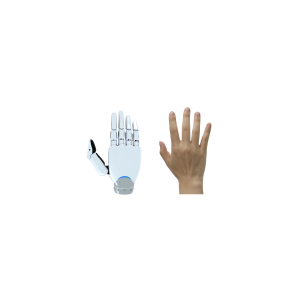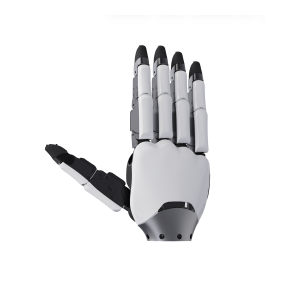


ROBOTERA XHAND 1 Dexterous Hand
$15,000.00
Five-finger fully driven dexterous hand with 12 active degrees of freedom, 15 N fingertip force and tactile sensing across all five fingertips.
Description
Product Overview
The ROBOTERA XHAND 1 is a fully driven five-finger dexterous hand for humanoid and robotic-arm manipulation. Its independently controlled joints, force control modes and three-dimensional fingertip tactile arrays support grasping, teleoperation and embodied AI research.
Highlights
- Twelve independently driven finger degrees of freedom
- Grasping, pinching, holding and twisting for manipulation research
- Five fingertip tactile arrays for three-dimensional force feedback
- Position, current-loop force and force-position control modes
Technical Specifications
| Weight | 1,100 g |
|---|---|
| Dimensions | 191 × 94 × 47 mm |
| Active degrees of freedom | 12 |
| Passive degrees of freedom | 0 |
| Fingertip force | 15 N |
| Maximum whole-hand grip force | 80 N |
| Maximum grasped mass, palm facing sideways | 16 kg |
| Maximum grasped mass, palm facing upward | 25 kg |
| Fingertip repeatability | ±0.20 mm |
| Repeated opening/closing speed | More than 2 Hz |
| Tactile sensors | Five fingertip arrays with three-dimensional force sensing |
| Tactile resolution | 12 × 10 per fingertip |
| Whole-hand control frequency | 83 Hz |
| Operating temperature | −20 °C to 60 °C |
| Operating voltage | 24–72 V |
| Communication | RS-485 (USB) and EtherCAT |
| No-load grasp cycle life | 1 million cycles |